
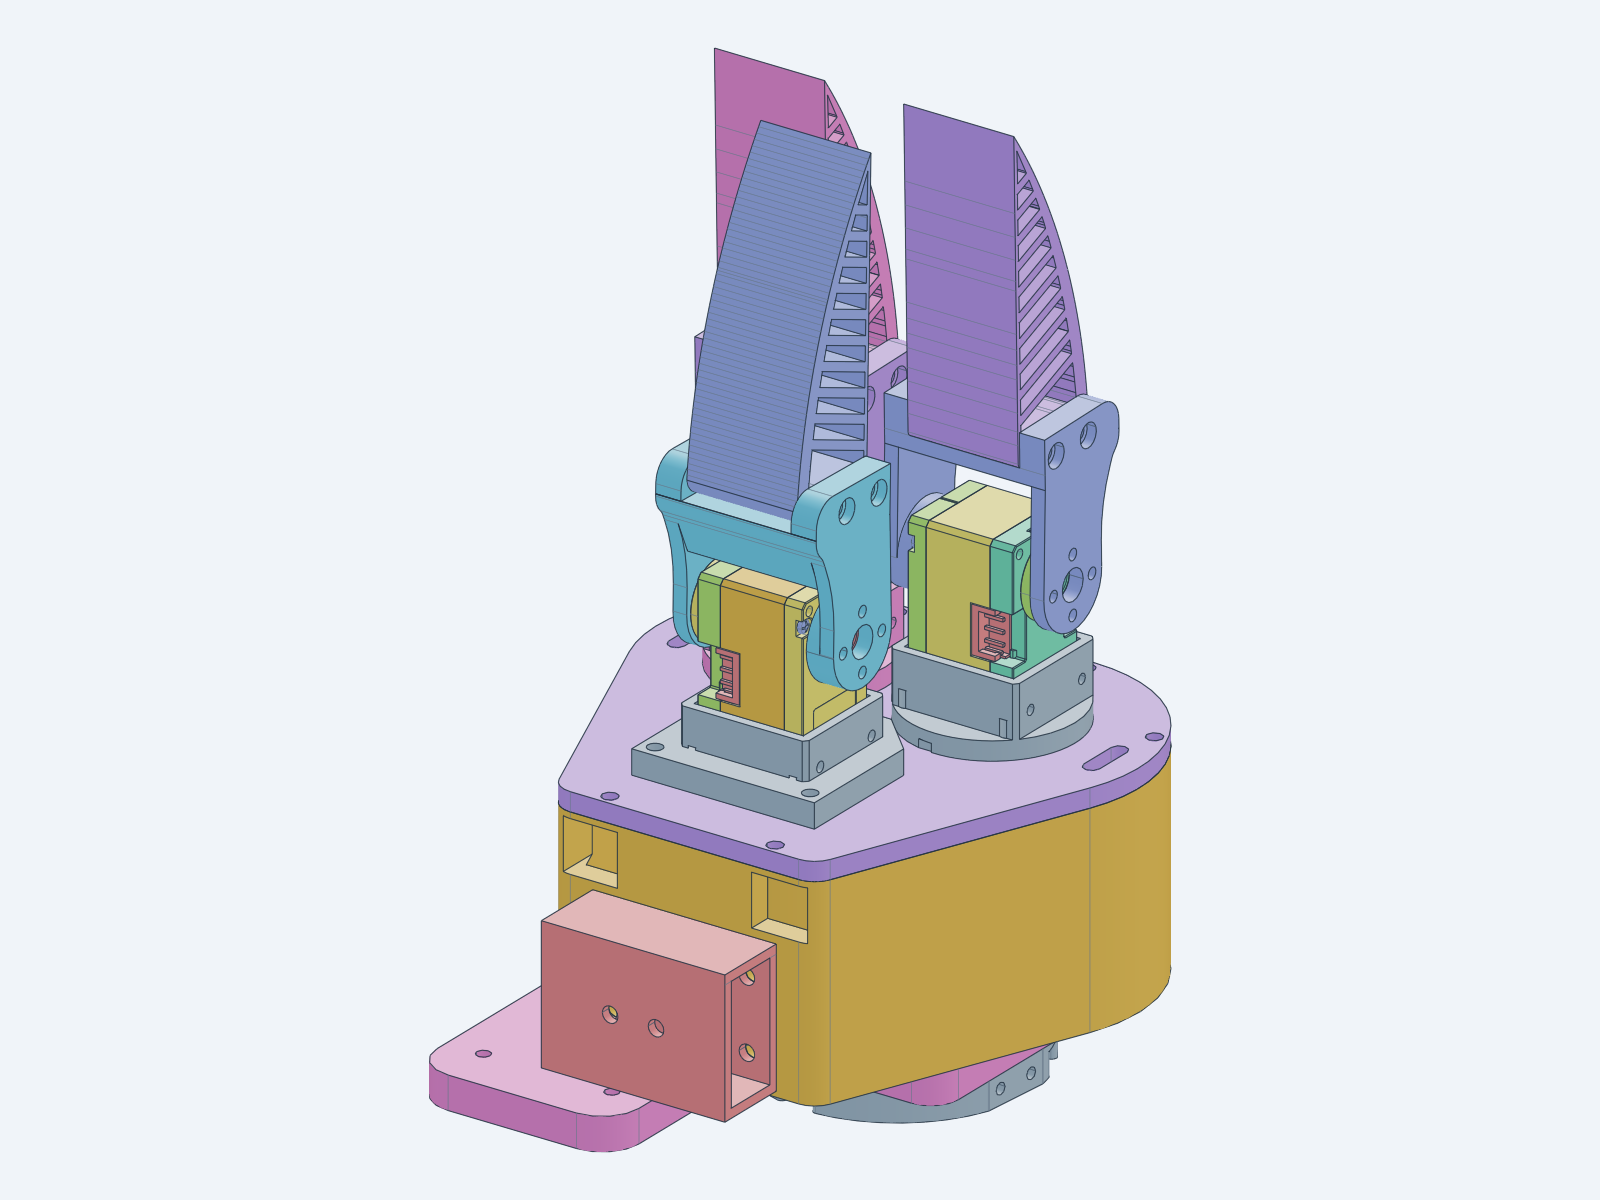
3-finger hand on four DYNAMIXEL XL330 servos: one per finger plus a geared spread drive, soft printed fingertips. Built and running on our robot; printable STLs, a demo video and a hosted step-by-step assembly guide.
Components (5)
DYNAMIXEL XL330-M288-TActuators (x4)
Geared Spread DriveMechanism — two turrets on F6803ZZ bearings, meshing printed gears
Soft-Fin FingersPrinted finger link + TPU fin (x3)
Waveshare Bus Servo Adapter (A)Servo interface, pocketed in the wrist plate
J7 Wrist Adapter + Camera DecouplerArm mount
Specifications
Fingers3 (two on spread turrets + fixed thumb)
DOF4 actuated: three finger flex + one spread (second spread finger geared −1:1)
Servos4 × DYNAMIXEL XL330-M288-T
InterfacesDYNAMIXEL Protocol 2.0, TTL half-duplex, 57,600 baud; Waveshare Bus Servo Adapter (A)
FingertipsSoft printed fins (TPU)
Travel~96–100° per joint as calibrated
Print bedAll parts fit a 256 × 256 mm bed
File formatsSTL (13 parts)
StatusReleased — built and running since 2026-10-15; demo video available; 3MF, photos and MJCF to come
Videos & Posts
VideoDemo video: picking up a plush bear on our mobile manipulator (2026-10-19)