
Open Source Robotics Lab
Open hardware we design — robots, dexterous hands, grippers, and sensor mounts — plus a curated map of the low-cost platforms we build on. Built by PathOn Robotics in collaboration with PathOnAI.org, an open-source AI and robotics research community.
A joint open-source effort
The hardware and software here are built by PathOn Robotics together with PathOnAI.org, an open-source AI and robotics research community. Its research volunteers work alongside our engineers on tracks like dexterous manipulation — several designs in this repo started there. Everything both sides produce ships open source, under permissive licenses, for anyone to build on.
Built by PathOn Robotics
Our own open hardware — CAD, printable STLs, and assembly guides in the repo.
 PathOn RoboticsEquipment
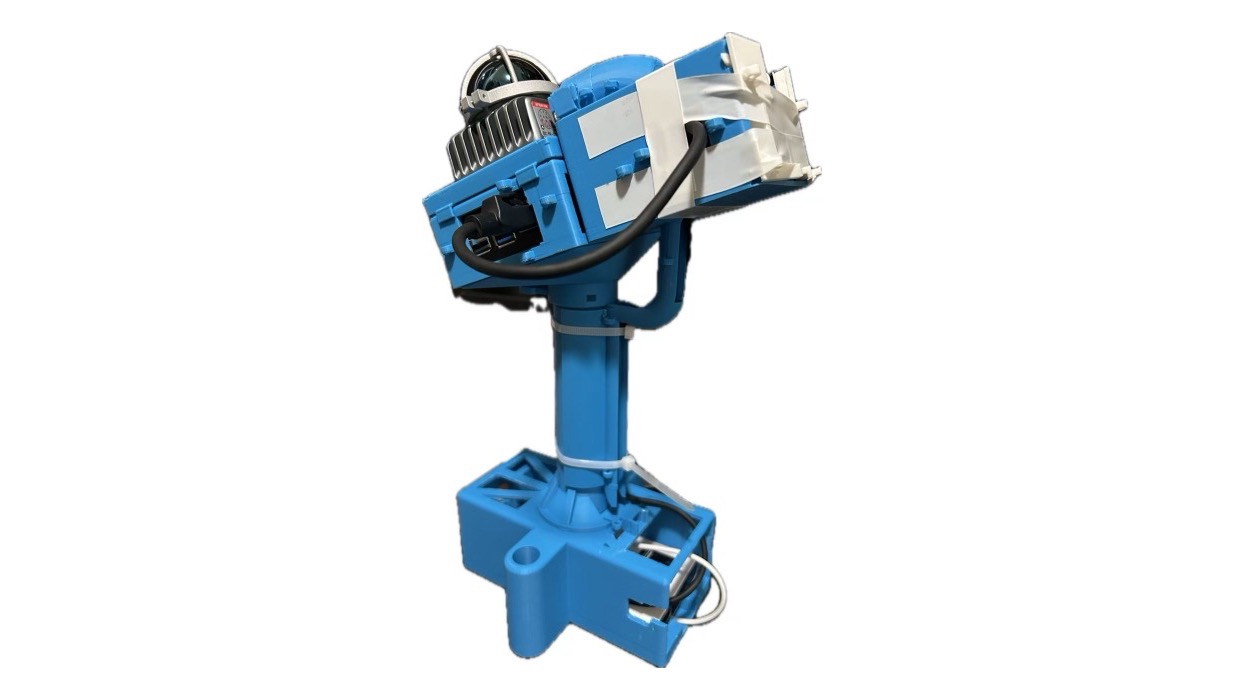
Handheld 3D LiDAR Scanner
3D-printable handheld enclosure that turns a Livox Mid-360 into a self-contained walk-around 3D scanner — sensor, Raspberry Pi 5, power bank, and 4G dongle in one printed body. Placeholder: built and working, files not yet released.
 PathOn RoboticsMount & Adapter
Livox Mid-360 Mount for Unitree Go2
3D-printable cantilever bracket that holds a Livox Mid-360 LiDAR forward of the Go2's head for an unobstructed 360° horizontal FOV.
OpenArm Leader Arm
3D-printable leader arm for teleoperating the 7-DOF OpenArm V2 — joint-position teleop at a fraction of the cost of the motorised leader that OpenArm's bilateral path requires. Placeholder: under development, nothing released.
 PathOn RoboticsRobot
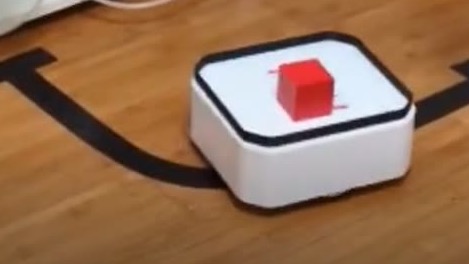
PathOn AGV — Line-Following Shuttle
Line-following shuttle from the Smart Logistics Cell — moves material within one work cell, arm to arm, along tape on the floor. No map, no localization. Placeholder: built and running, files not yet released.
 PathOn RoboticsRobot
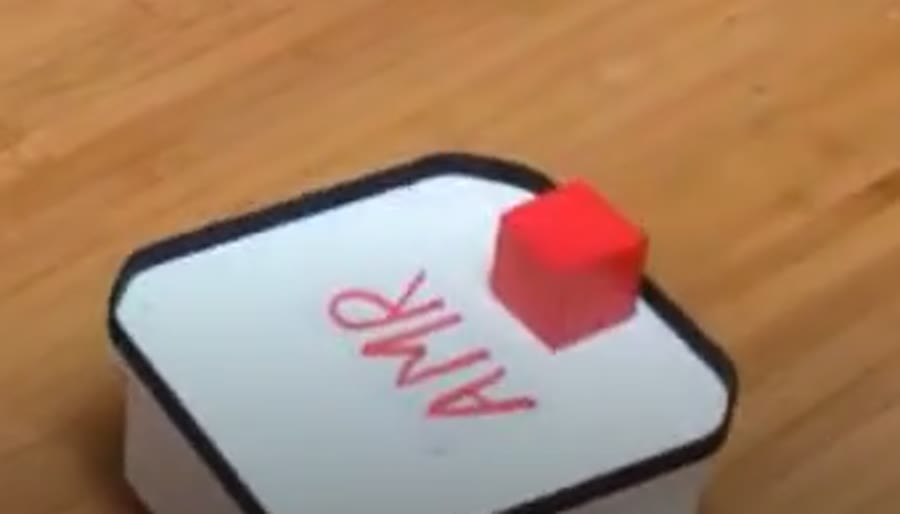
PathOn AMR — Autonomous Mobile Robot
Nav2 mobile robot from the Smart Logistics Cell — carries material between work cells, holds a map, plans its own path, and routes around obstacles. Placeholder: built and running, files not yet released.
 PathOn RoboticsEquipment
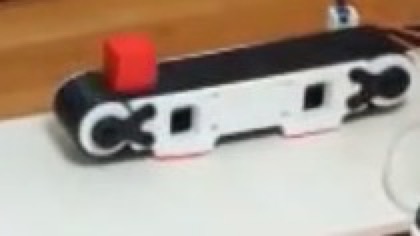
PathOn Conveyor — Sensor-Triggered Infeed
3D-printed belt conveyor that feeds the Smart Logistics Cell — carries a block to an IR-monitored pick point, where the sensor firing starts the whole line. Placeholder: built and running, files not yet released.
 PathOn RoboticsEnd Effector
PathOn Dexterous Hand V1
3-finger servo-actuated hand built around 7 DYNAMIXEL XL330-M288-T servos — research-grade feedback, printable CAD/STL/3MF.
 PathOn RoboticsEnd Effector
PathOn Dexterous Hand V2
Compact 3-finger hand built on Feetech SCS0009 micro servos — smaller and lighter than V1, with a prepared print plate.
 PathOn RoboticsEnd Effector
PathOn Dexterous Hand V3 — Barrett-Style
Barrett-style underactuated hand: 8 joints driven by 4 DYNAMIXEL servos. CAD assembly and the first printable STLs are released; 3MF, sim models and assembly docs are still to come.
 PathOn RoboticsRobot
Piper Leader Arm
3D-printable 6-DOF leader arm for teleoperation, built around Feetech SCS215 serial bus servos with a squeeze trigger at the wrist.
 PathOn RoboticsRobot
SO-101 6DoF Arm
The SO-101 arm upgraded from 5DoF to 6DoF — two printed wrist links (pitch + yaw) and one added STS3215 servo, so the arm can approach objects from any angle.
 PathOn RoboticsEnd Effector
Symmetric Gripper
Rack-and-pinion parallel-jaw gripper where both fingers move equally, giving balanced grasping force for reliable pick-and-place.
Robots
Actuated machines you can drive on their own.
Software
Tools that run in your browser, and the open-source code behind our robots.
Point Cloud Viewer
Upload and visualize PLY point cloud files in 3D directly in your browser. Supports ASCII and binary formats with vertex colors.
3D Gaussian Splatting Viewer
Upload a trained Gaussian Splatting .ply (e.g. from Nerfstudio's splatfacto) and render it in-browser with WebGL2. Supports .ply, .spz, .splat, and .ksplat.
Agentic DIY Robot Pipeline
End-to-end “bring your own robot” pipeline: text → CAD → URDF/MJCF → end-effector attach → ROS 2, driven by coding agents.
iPhone Sensor Suite
Use an iPhone as a full sensor suite (LiDAR, RGB, IMU) for robot manipulation and navigation — iOS app, Python SDK, ROS 2 driver, and calibration.